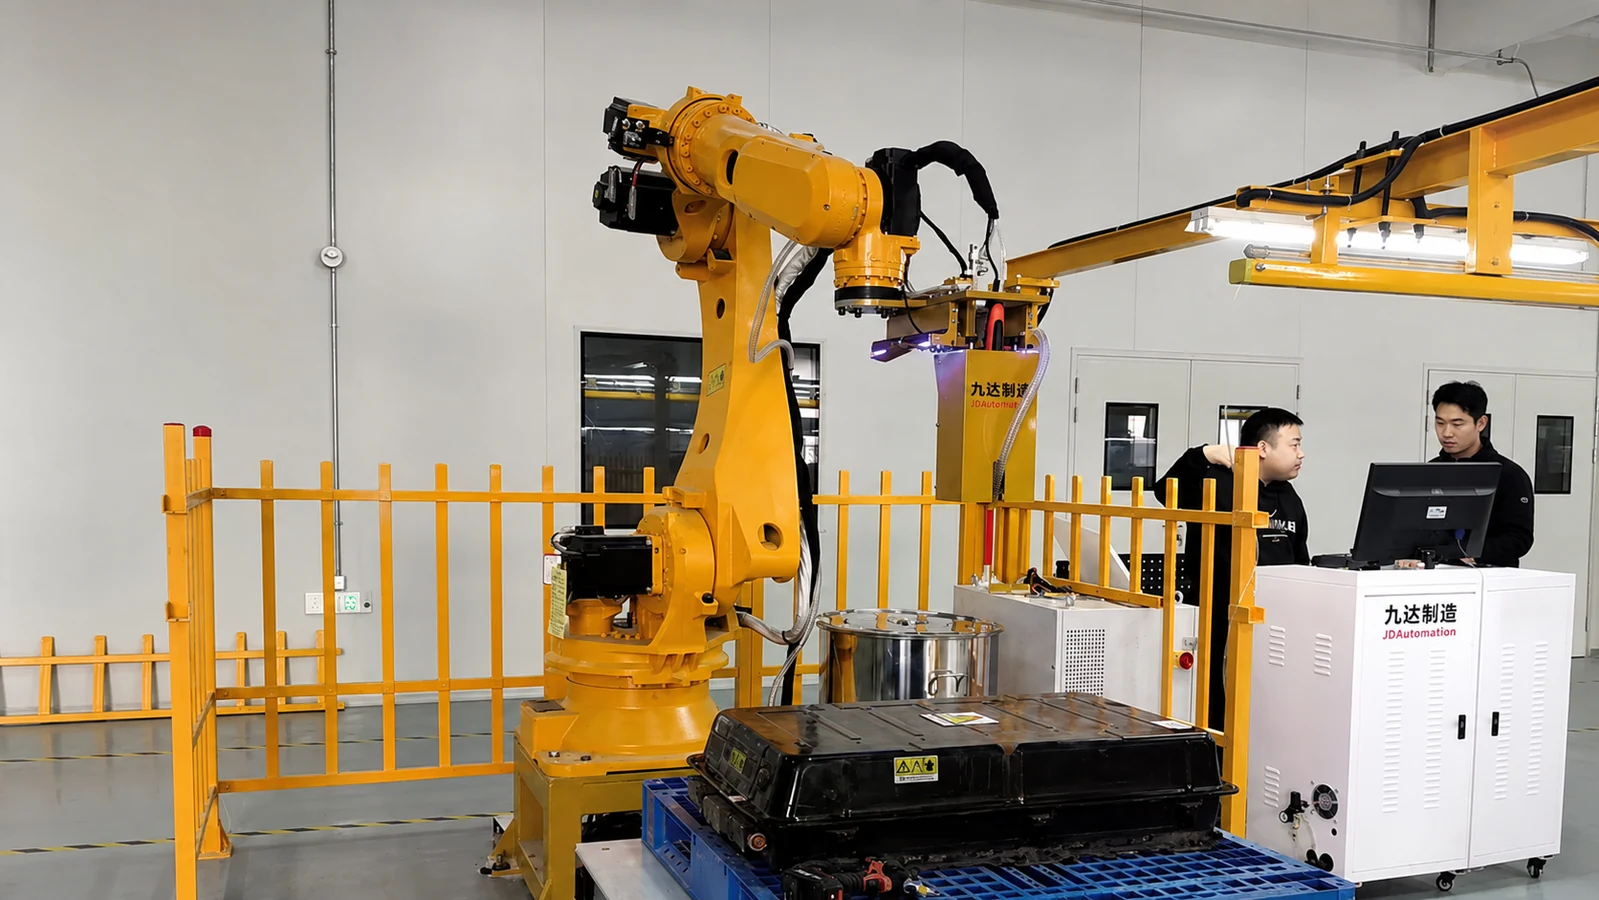
Robotic top-cover station
A six-axis robot and removal tool handle pack top-cover fasteners ahead of cover separation.
Applications & configuration
- Compatibility is evaluated against fasteners and pack structure.
- The system locates the fasteners, then removes them with dedicated tooling.
- Suitable for fixed stations or flexible disassembly cells.
Robot, sensing and controls
The station combines a robot, removal tooling, position sensing and controls. Detection identifies the top cover and fastener positions and conditions, while the controller coordinates robot motion, tool actions and station interlocks.
Programs and tools are selected for screw types, counts and positions, together with pack clamping and positioning. Changeovers require tools, fixtures, inspection conditions and programs matched to the incoming pack.
Cover removal and service applications
After fastener removal, the station can connect to cover handling and subsequent pack disassembly. It can be a fixed station or part of a flexible cell combining AGVs and robots.
Assembly or maintenance applications require separately configured fastening operations, tool settings and inspection methods. Selection also considers feedstock condition, abnormal fasteners and the required cycle time.
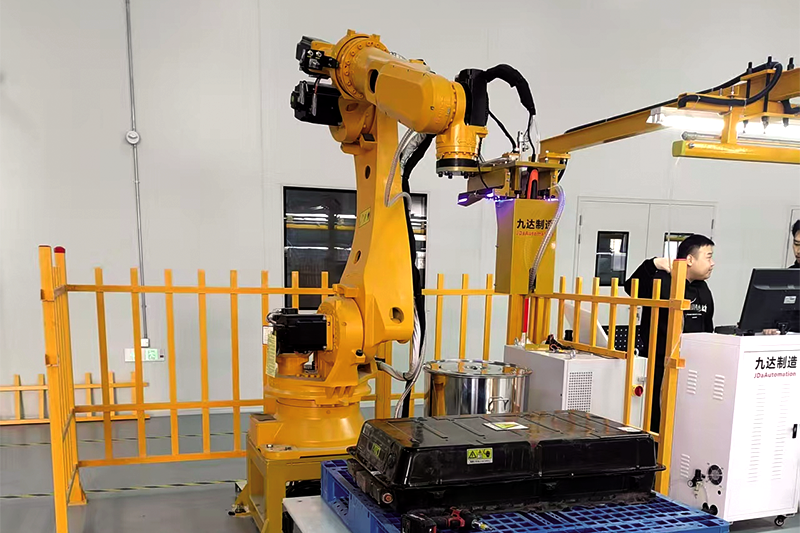
Equipment photographs
Related equipment & configurations
Equipment selection and line enquiries
Share your battery type, processing goals and site conditions so we can assess the process.